Compare robots 1 robots · up to 4
| Specification | 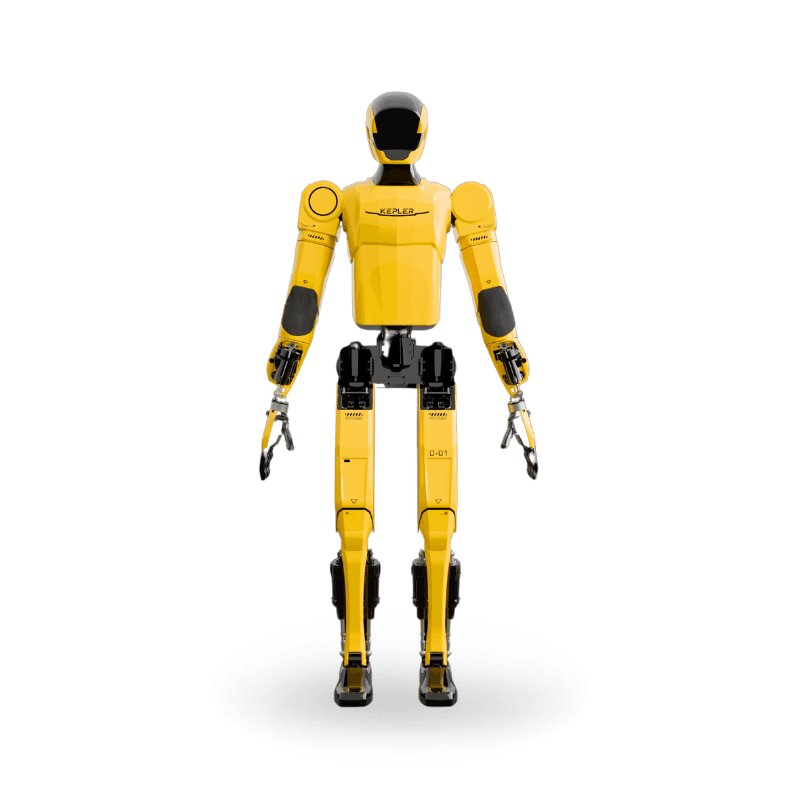 开普勒探索 开普勒先行者 K2 双足开发版双足人形 官方未公布双足开发版固定售价;请向开普勒机器人获取人民币报价 |
|---|---|
| Basic Information | |
| Positioning / Application | 科研教育、二次开发、具身智能数据采集与展示;双臂协同搬运能力 25–30 kg,支持视觉 SLAM、多模态交互和手眼协同 |
| Release Date | — |
| Country | 中国 |
| Model Alias | K2 大黄蜂双足开发版 |
| Made In | 中国 |
| Overall Specifications | |
| Weight (kg) | 75 |
| Height (mm) | 1750 |
| Material | — |
| Noise Level (dB) | — |
| Width (mm) | — |
| Folded Dimensions (mm) | — |
| Locomotion Type | biped |
| Color | — |
| Motion Performance | |
| Max Speed (m/s) | — |
| Payload (kg) | — |
| Peak Joint Torque (N·m) | 220 |
| Max Gradient (°) | — |
| Max Step Height (cm) | — |
| Jumping Capability (m) | — |
| Degrees of Freedom | |
| Total DOF (DOF) | 52 |
| Waist DOF (DOF) | — |
| Mechanical Structure | |
| Joint Type | 行星滚柱丝杠、旋转与微型执行器组成的串并联混合架构 |
| Joint Encoder | — |
| Joint Range of Motion | — |
| Sensors | |
| Sensors | 视觉与听觉传感器、每腕六维力传感器、柔性触觉传感器及惯性传感器 |
| Camera | — |
| LiDAR | — |
| IMU | — |
| Obstacle Avoidance | — |
| Battery & Endurance | |
| Battery Capacity (Wh) | — |
| Runtime (h) | 8 |
| Charging Time (h) | 1 |
| Battery Voltage (V) | — |
| Power Supply (V) | — |
| Hot-swappable | — |
| Charging Power (W) | — |
| Charging Method | — |
| Compute Platform | |
| Onboard Compute | 100 TOPS GPU |
| AI Compute Module | 100 TOPS GPU,支持算力升级 |
| Compute (TOPS) (TOPS) | 100 |
| Operating System | 开普勒星云(Nebula)具身智能系统 |
| CPU Cores (核) | — |
| Safety & Environment | |
| Ingress Protection (IP) | — |
| Operating Temperature (°C) | — |
| Pinch Protection | — |
| Interaction & Communication | |
| Communication | — |
| Microphone | — |
| Speaker | 标配 |
| Lighting | — |
| Voice Interaction | — |
| OTA Update | — |
| Development & Expansion | |
| Secondary Development (SDK) | 配套二次开发平台,支持运动、视觉与语音模块、可视化编程、多机协同、在线调试与 OTA |
| Expansion Backplane | — |
| App Platform | — |
| Commercial Information | |
| Warranty (年) | 1 |