Compare robots 1 robots · up to 4
| Specification | 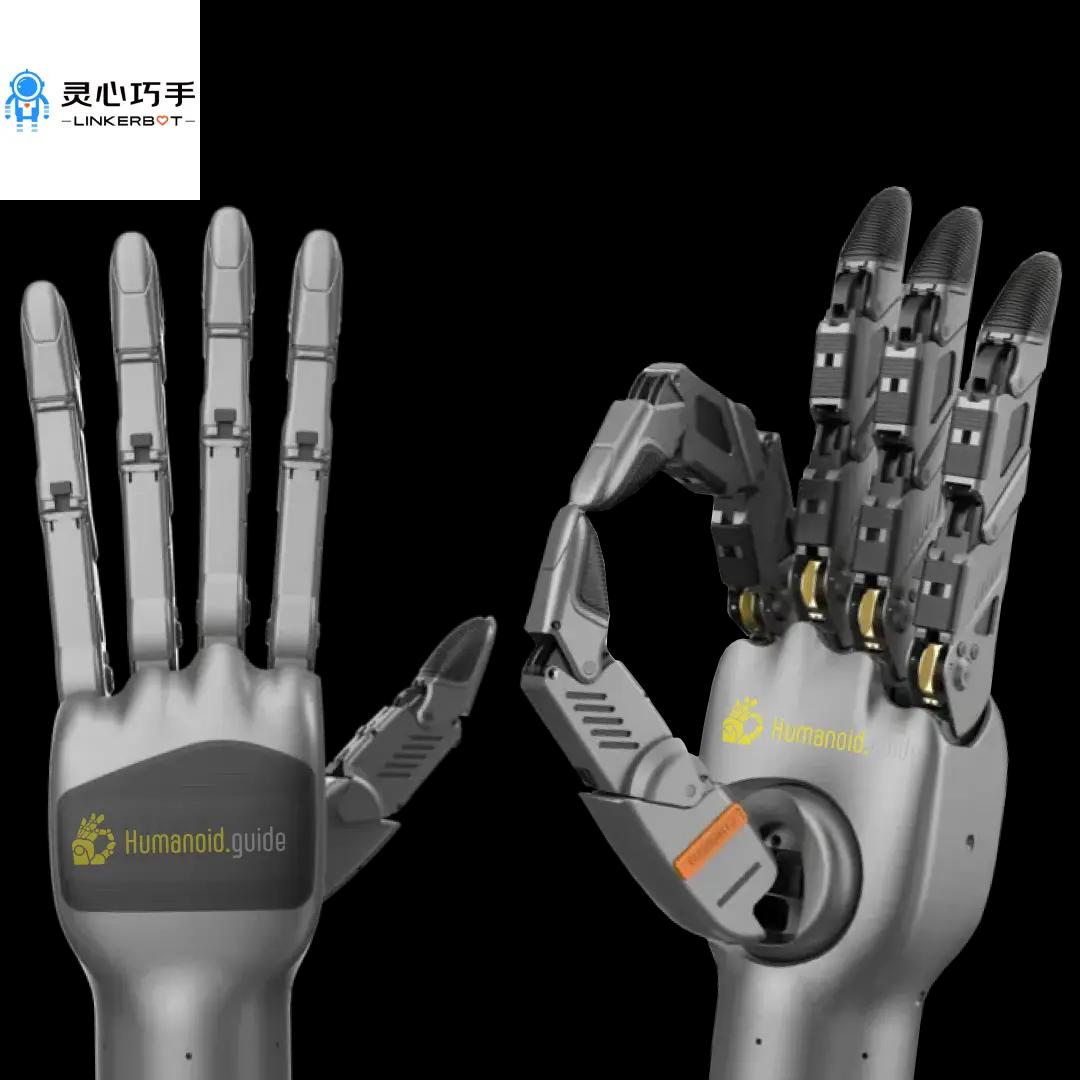 LINKERBOT Linker Hand R30Dexterous Hands 联系 LINKERBOT 获取官方报价 |
|---|---|
| Basic Information | |
| Positioning / Application | Fully direct-drive five-finger dexterous hand for humanoid integration, high-precision robotics research and adaptive industrial manipulation |
| Release Date | — |
| Country | 中国 |
| Model Alias | Linker Hand R30 |
| Made In | — |
| Overall Specifications | |
| Weight (kg) | — |
| Height (mm) | — |
| Material | — |
| Noise Level (dB) | — |
| Width (mm) | — |
| Folded Dimensions (mm) | — |
| Locomotion Type | — |
| Color | — |
| Motion Performance | |
| Max Speed (m/s) | — |
| Payload (kg) | — |
| Peak Joint Torque (N·m) | — |
| Max Gradient (°) | — |
| Max Step Height (cm) | — |
| Jumping Capability (m) | — |
| Degrees of Freedom | |
| Total DOF (DOF) | 21 |
| Waist DOF (DOF) | — |
| Mechanical Structure | |
| Joint Type | Fully direct-driven finger joints with self-developed joint actuators |
| Joint Encoder | — |
| Joint Range of Motion | — |
| Sensors | |
| Sensors | Pressure, tactile and visual-tactile sensing; high-density full-hand tactile coverage |
| Camera | — |
| LiDAR | — |
| IMU | — |
| Obstacle Avoidance | — |
| Battery & Endurance | |
| Battery Capacity (Wh) | — |
| Runtime (h) | — |
| Charging Time (h) | — |
| Battery Voltage (V) | — |
| Power Supply (V) | — |
| Hot-swappable | — |
| Charging Power (W) | — |
| Charging Method | — |
| Compute Platform | |
| Onboard Compute | — |
| AI Compute Module | — |
| Compute (TOPS) (TOPS) | — |
| Operating System | — |
| CPU Cores (核) | — |
| Safety & Environment | |
| Ingress Protection (IP) | — |
| Operating Temperature (°C) | — |
| Pinch Protection | — |
| Interaction & Communication | |
| Communication | — |
| Microphone | — |
| Speaker | — |
| Lighting | — |
| Voice Interaction | — |
| OTA Update | — |
| Development & Expansion | |
| Secondary Development (SDK) | — |
| Expansion Backplane | — |
| App Platform | — |
| Commercial Information | |
| Warranty (年) | — |